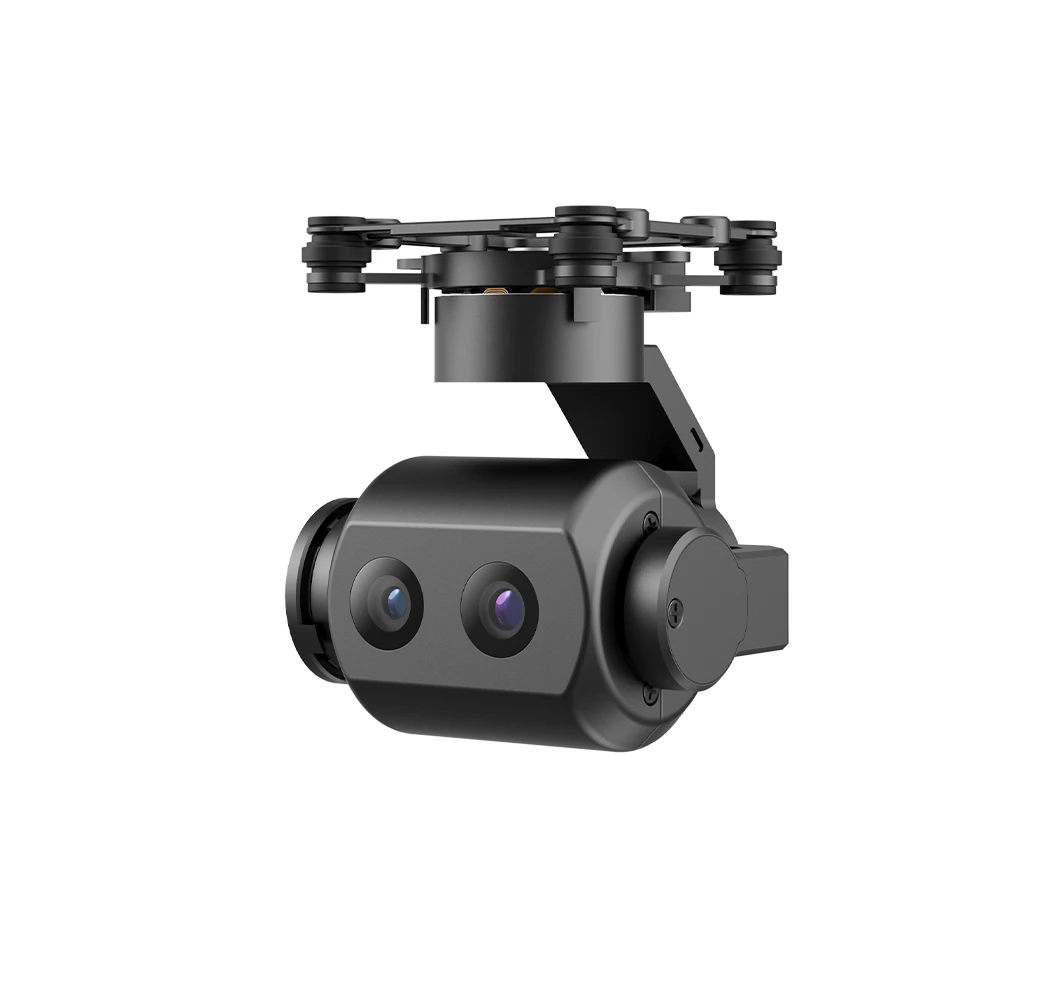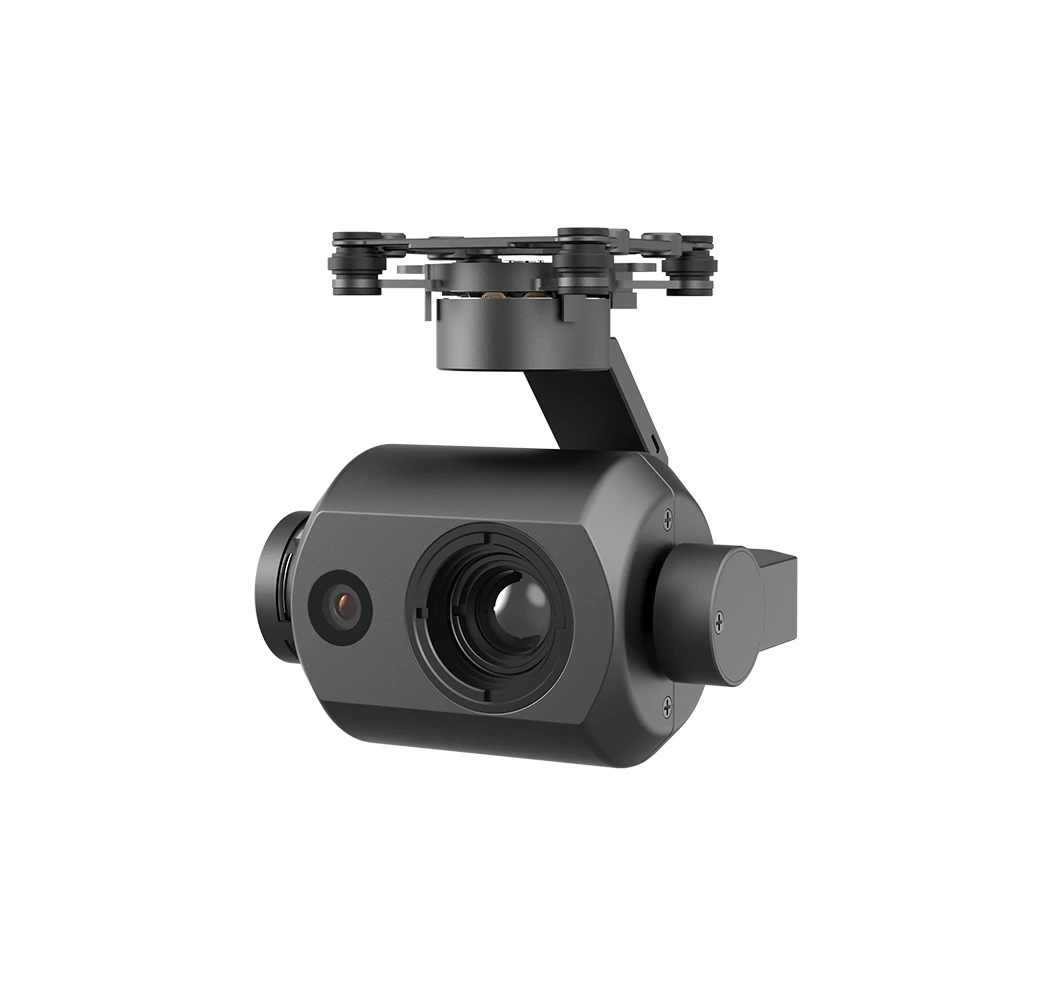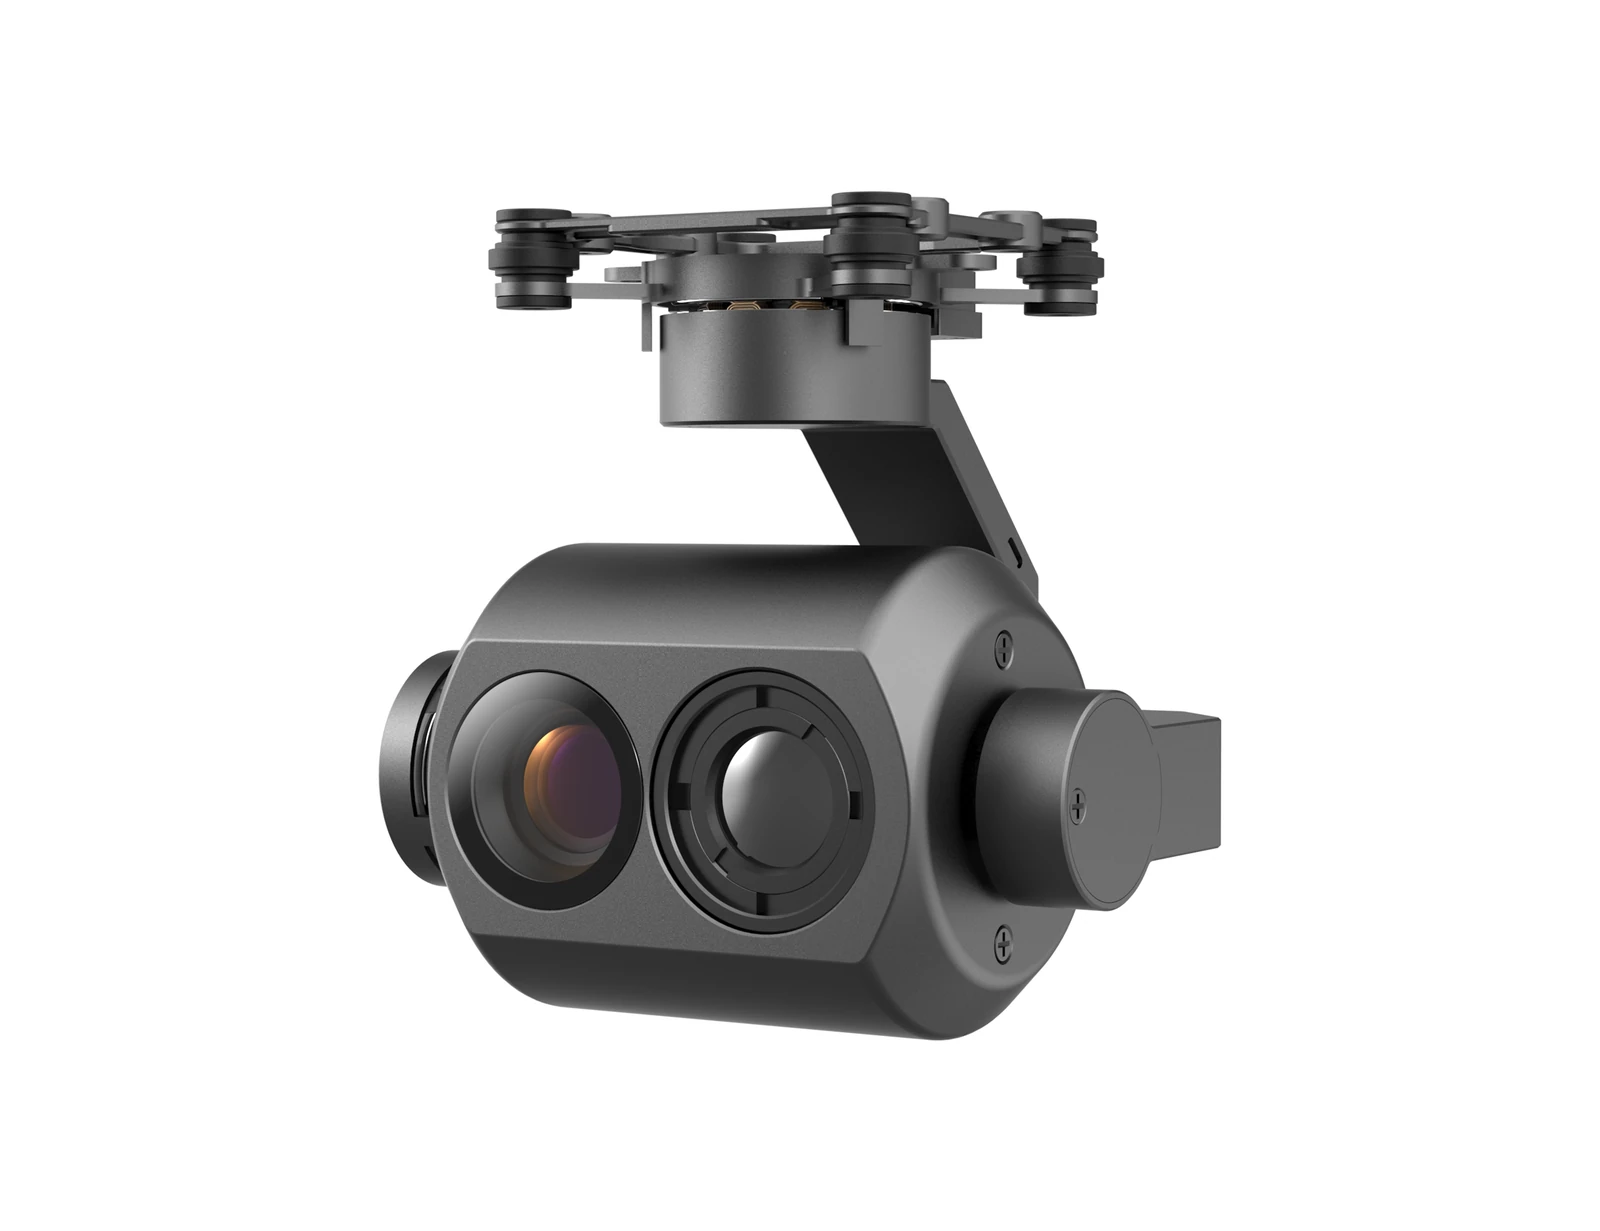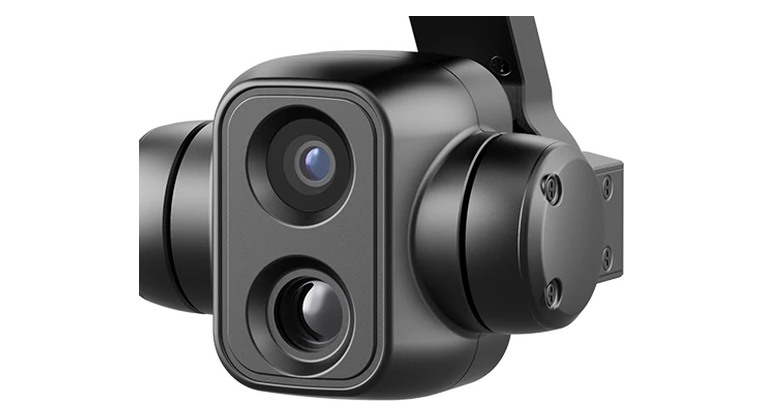
bifocal lens
50 million pixels visible light + infrared coaxial
Visible light 4.7 mm (F1.7), infrared 7 mm, the same orientation, the two images do not need to be aligned; supports 30× digital zoom.
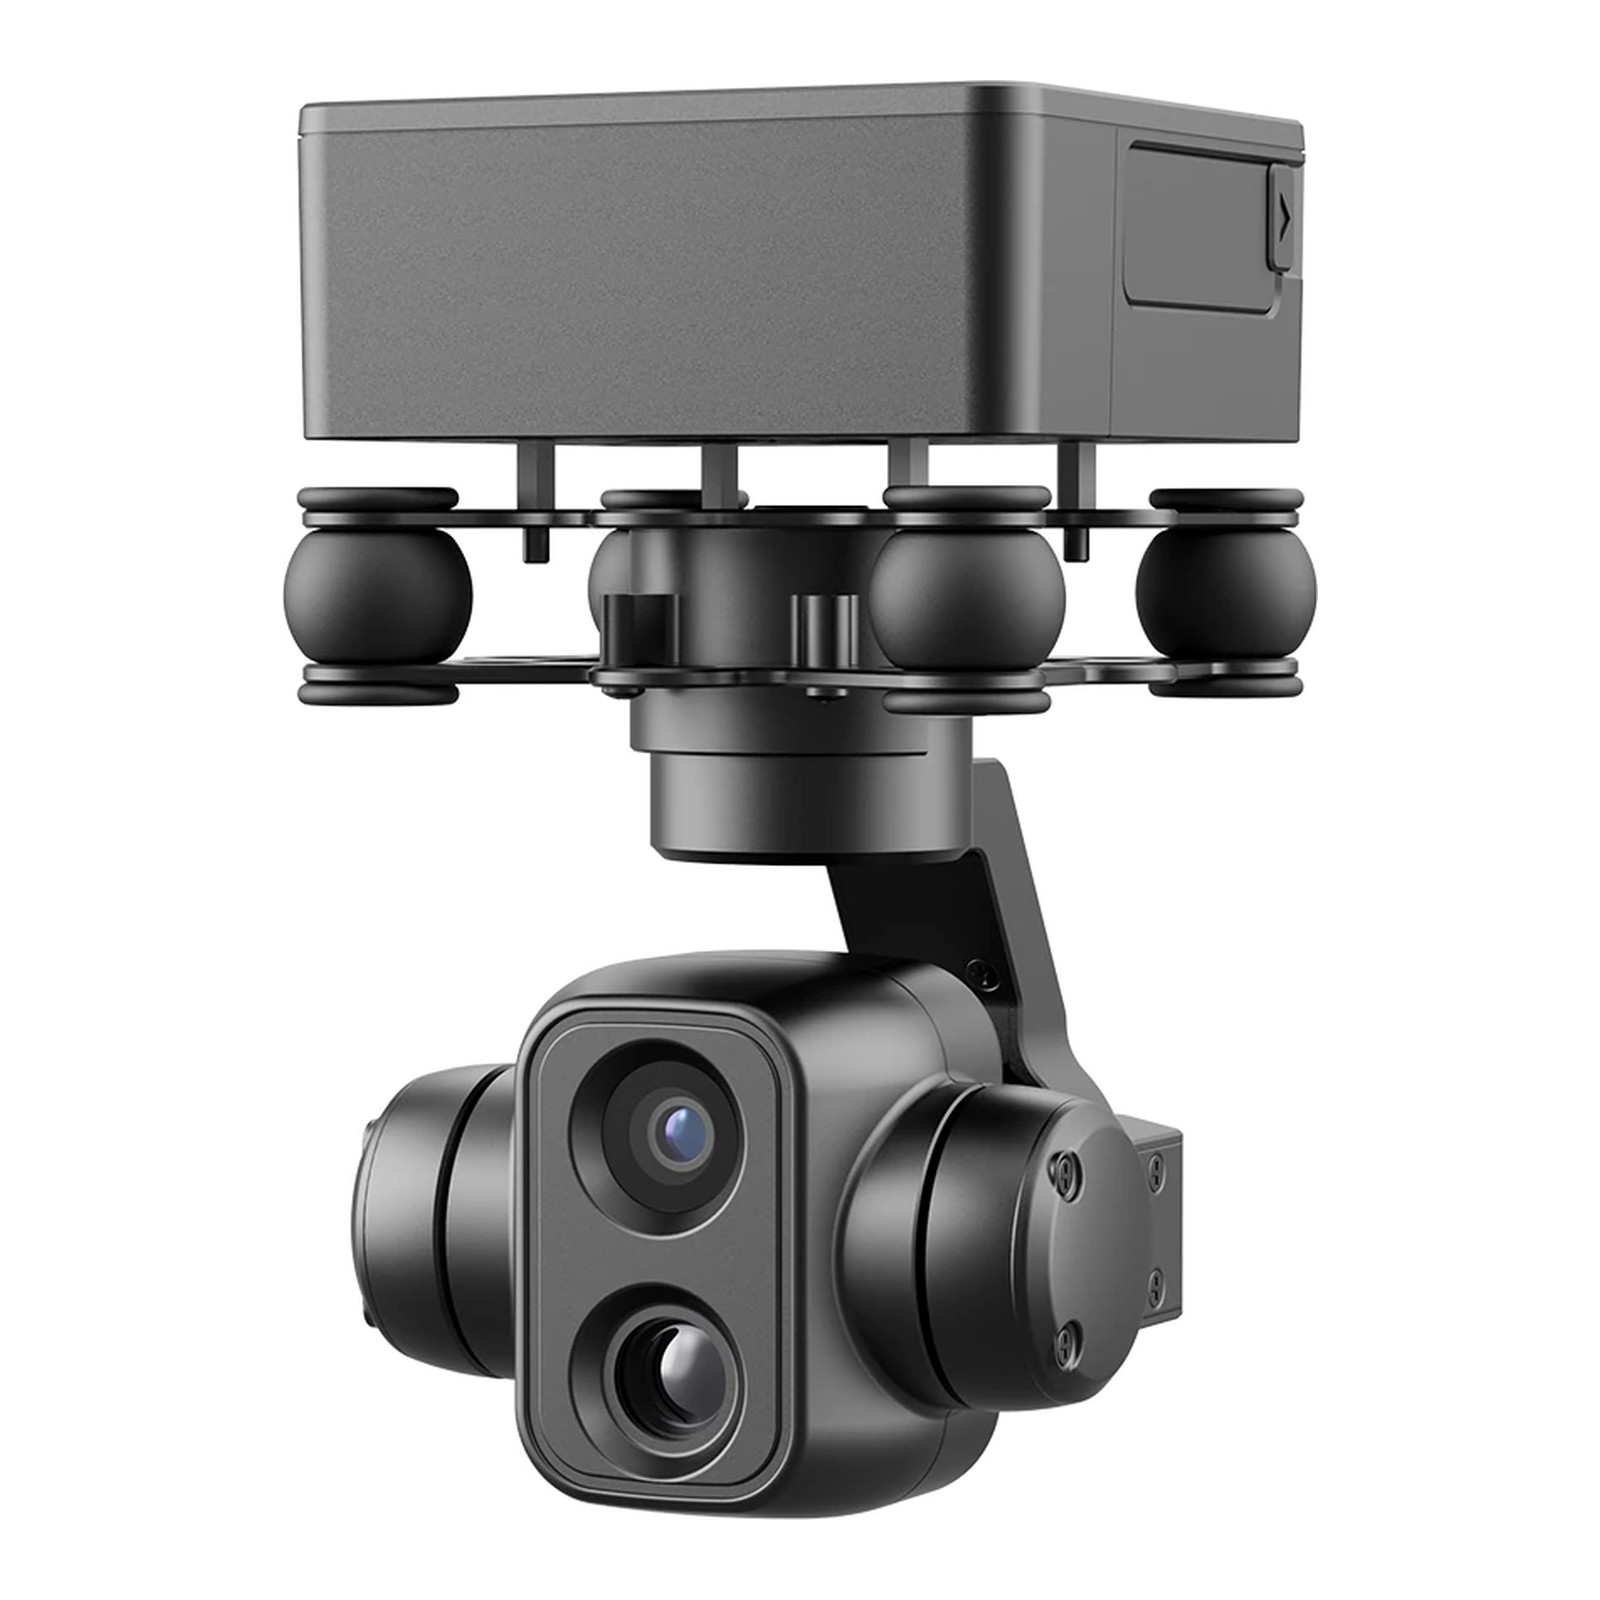
Stable image gimbal · three-axis dual-sensor
Image stabilization accuracy ≤ 0.02° (1σ, disturbance 0.5°@1Hz), effective 48 million pixel visible light + 384×288 infrared output simultaneously; gimbal 104 g , and can also provide target guidance signals.
50 MP visible + 384×288 infrared, dual simultaneous output.
30× digital zoom, daytime adult recognition >400 m, nighttime >90 m; three-axis stabilization ≤0.02°, target positioning CEP 10 m, gimbal only 104 g.
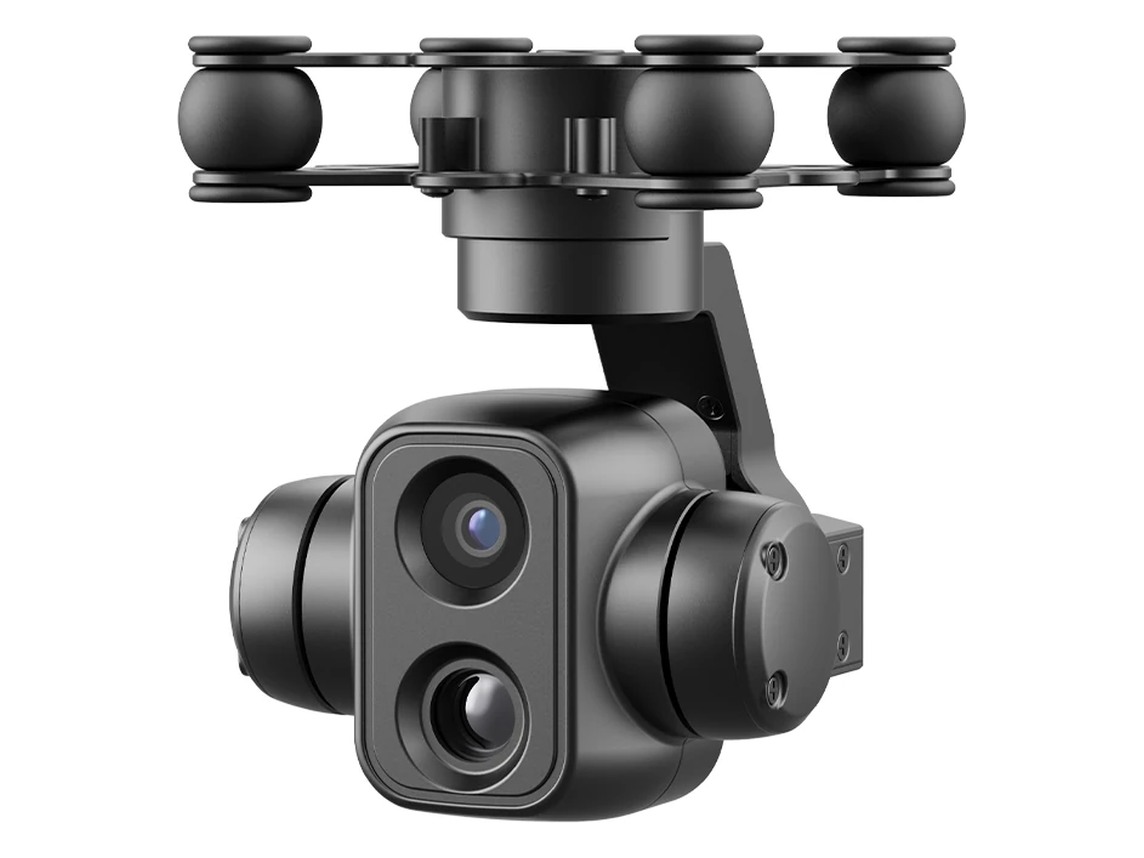
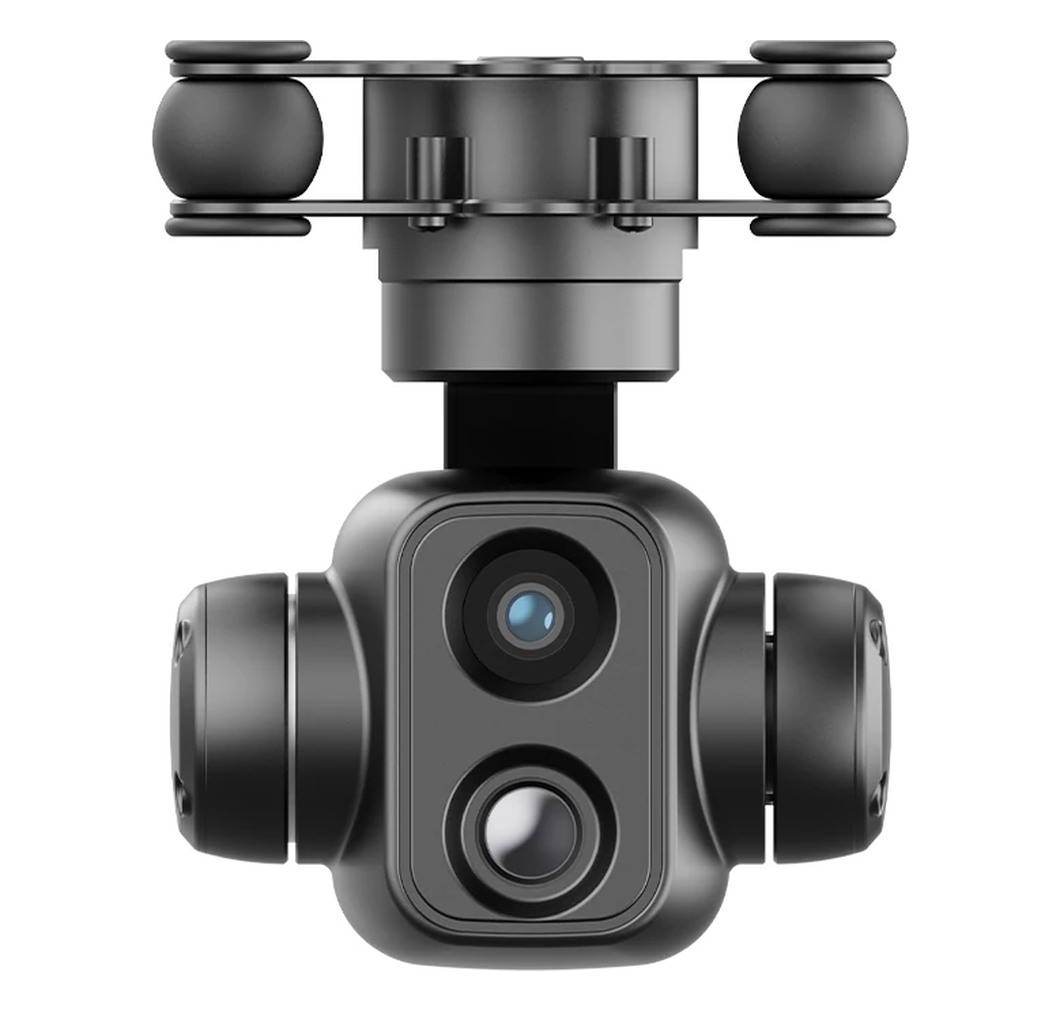
104 g three-axis gimbal, 58×57×79 mm, azimuth ±90°, pitch -90°~+30°.
Guidance ability
Dual-sensor fusion performs target detection, recognition, locking and tracking, and the output is a real-time guidance signal - the flight controller obtains the target position, not a picture. Infrared supports multiple pseudo-color modes, and the outline can still be distinguished in darkness, smoke, and partial occlusion, and it can operate continuously day and night.
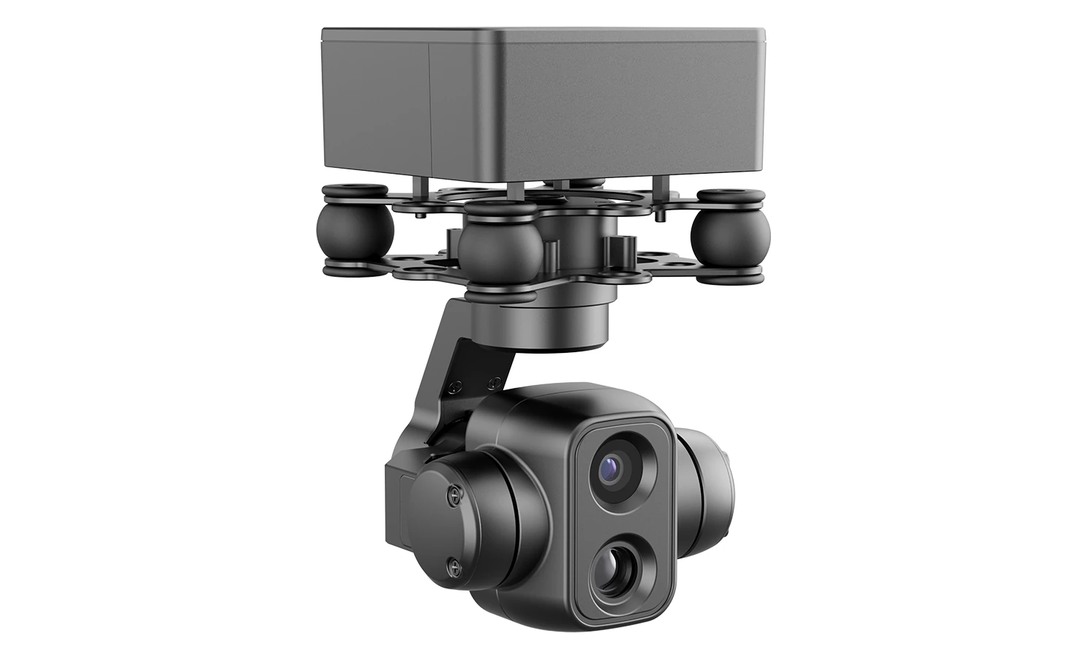
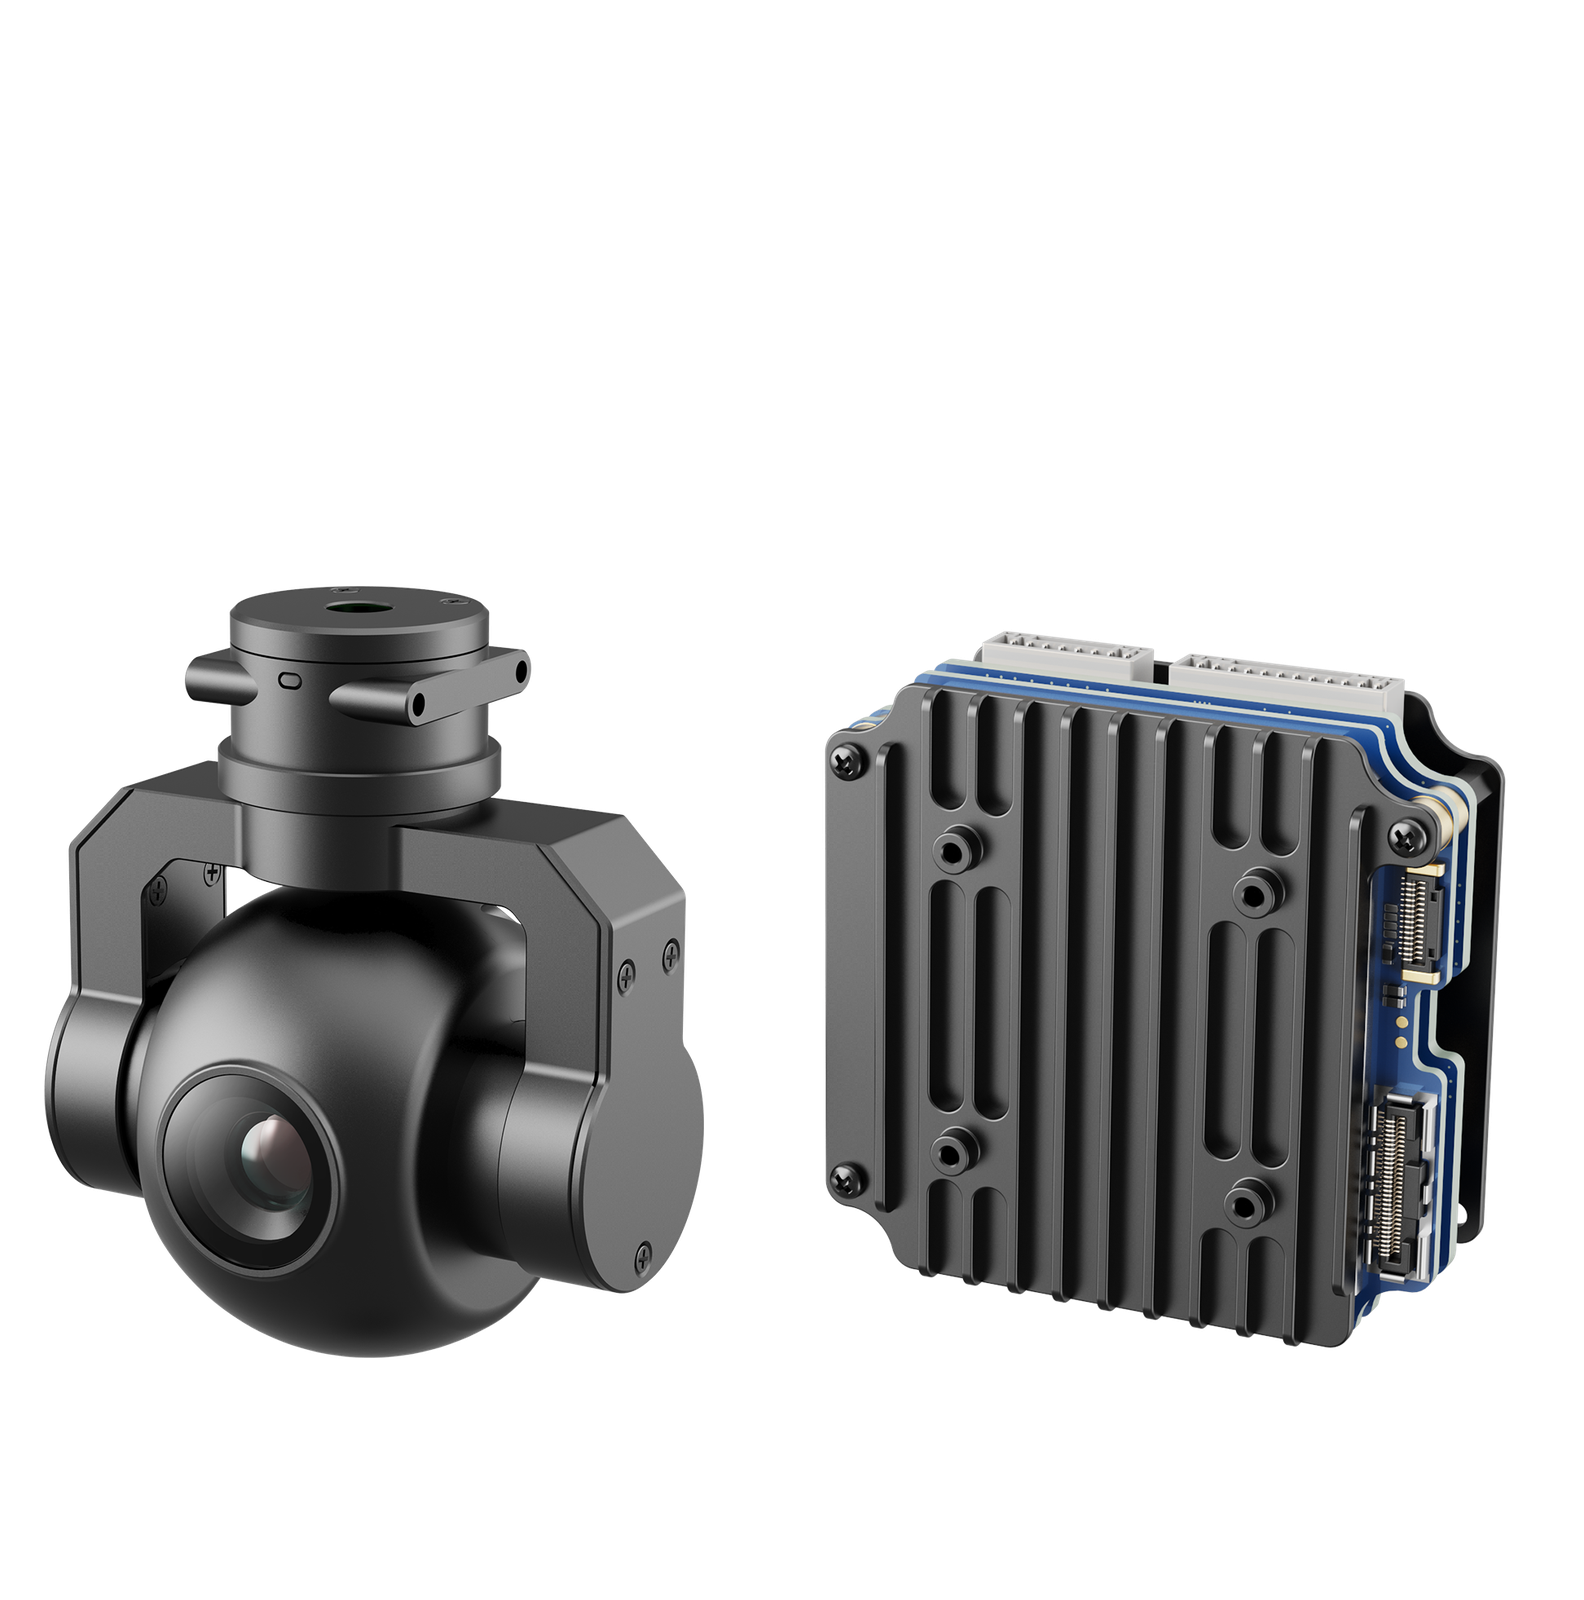
The lens is responsible for viewing, the gimbal is responsible for stabilization, and the control box and shock-absorbing mount keep vibration out.
Visible light 4.7 mm (F1.7), infrared 7 mm, the same orientation, the two images do not need to be aligned; supports 30× digital zoom.
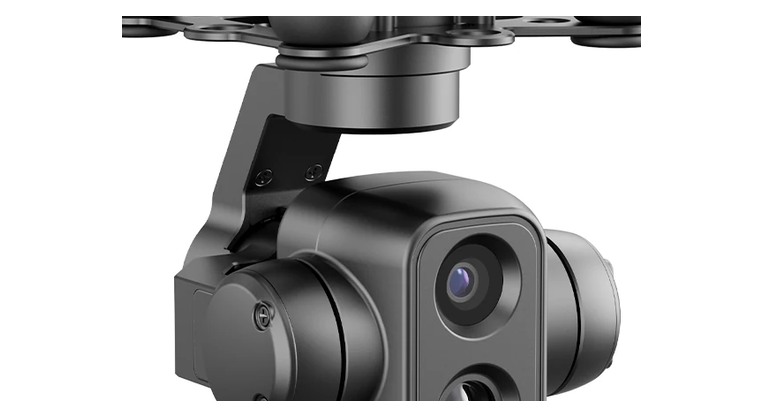
Controllable range azimuth ±90°, pitch -90°~+30°, image stabilization ≤0.02°, servo + tracker 42 g (mandatory).
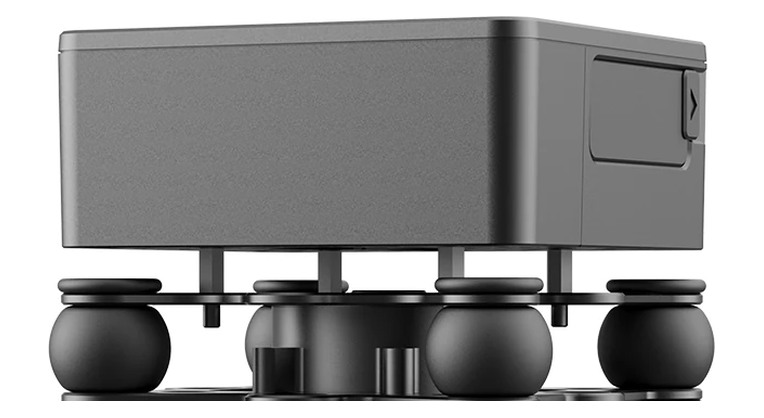
Control box 59×55×24 mm, 23 g, optional; four-corner rubber shock-absorbing balls first block the vibration of the body, and then the gimbal stabilizes the image.
Urban security, emergency response, industrial and power inspections, and border lines are all scenes that "people want to see clearly but don't want to get close to."
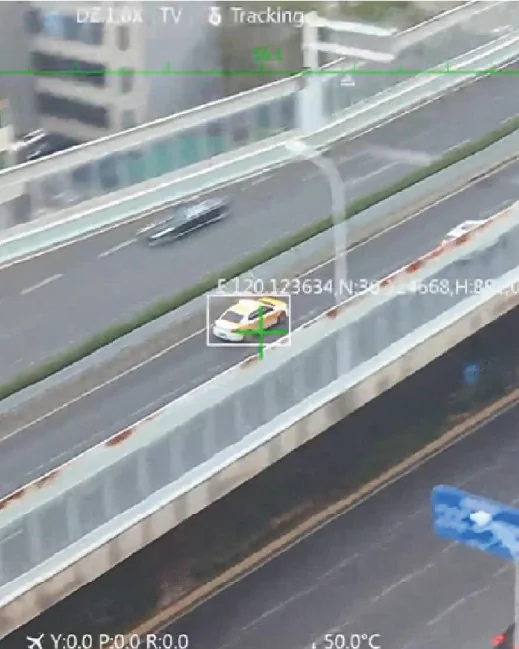
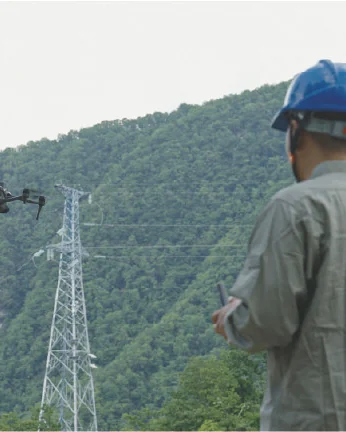
Pictures only represent the working environment, not specific customer projects.
The recognition distance is strongly related to visibility, humidity, and temperature difference, and should be understood according to the labeling conditions; optional items are confirmed according to the order.
| sensor | 1/2.5" CMOS, 50 million pixels (48 million effective) |
|---|---|
| lens | 4.7 mm, F1.7 |
| field of view | 59.5° (H) × 35.5° (V) (±5%, 1080P) |
| take pictures | 8K/4K/1920×1080 |
| Video | 4K @50fps, 1920×1080 @50fps |
| zoom | 30× digital zoom |
| Recognition Range (Day) | Adult target >400 m (daytime visibility ≥8 km, humidity ≤60%) |
| response band | 8~14 μm, long wave |
|---|---|
| resolution | 384 × 288 |
| Lens Focal Length | 7mm |
| field of view | 24.8° (H) × 18.7° (V) (±5%, 1080P) |
| Frame rate | 384×288 @50fps |
| NETD | ≤50 mK (@25°C F#1.0) |
| Recognition Range (Day) | Adult target >90 m (night, visibility ≥8 km, humidity ≤60%, background temperature difference ≥5 K) |
| False color mode | White hot / black hot / iron red / golden red / rainbow / aurora / medical / jungle |
| Stabilization Accuracy | ≤0.02° (preview 0.1°Hz) |
|---|---|
| Frame design scope | Azimuth ±110°, roll ±50°, pitch ±120° |
| Controllable rotation range | Azimuth ±90°, pitch -90°~+30°, roll ±45° |
| Gimbal Weight | 104g±5g |
| Servo + Tracker | 42 g ± 2 g (required) |
| Targeting | CEP 10m |
| Video Output | HDMI / network / coaxial |
|---|---|
| Video Codec | H.264 / H.265 |
| Video Stream | 2M / 4M |
| Storage | Micro SD card |
| Power Supply | DC10.8V ~ 26.4V @ 3A |
|---|---|
| Power Consumption | Steady state ≤10 W |
| Control Interface | TTL serial, network, SBUS |
| Gimbal Dimensions | 58.0 × 57.0 × 79.0 mm |
| Control box (optional) | 59.0×55.0×24.0 mm, 23 g ± 2 g |
| Operating Temperature | -20°C to +55°C |
| Storage Temperature | -45°C to +60°C |
Short answer, no sales talk. Your question was not found, please go directly to the form at the bottom of the page.
Calculated, the amplitude of screen jitter at a distance of 1 kilometer is about 0.35 meters. At this level, there is basically no shaking in the 4K picture, and the telephoto is stable even when looking far away.
no. The gimbal body weighs 104 g, the servo controller + tracker weighs 42 g (mandatory), and the control box 23 g is optional. When installing, the weight and position of these three parts should be reserved together.
Use wide angle to frame the scene first, use 8K/4K to leave a margin for cropping, and pick out details later; if you want to see the picture continuously, use 1080P@50fps, and the code stream is 2M/4M.
90 meters is the distance for "recognizing an individual", provided that the visibility is 8 km, the humidity is ≤60%, and the background temperature difference is ≥5 K. You can get farther by looking at the outline and finding the heat source, but that doesn't count as identification, so don't mess with it when quoting.
Power supply 10.8–26.4V @3A, steady state ≤10W, interface is TTL serial port/network/SBUS. Send us the model and load position dimensions, and we will make a plan after confirming the adapter and power supply.
Tell us the machine model, load position size and working distance, and give us a quote after confirming the adapter and power supply.
They are all image stabilization routes, selected according to the number of channels, infrared resolution and weight.